
Application cases · Large-box handling
Mobile Vacuum Handling of Large Packaging Boxes
A mobile-base pneumatic industrial manipulator with custom vacuum tooling using side and top suction cups assists with pickup, lifting, direction changes and placement of large packaging boxes. The operator guides box transfer, reducing manual carrying and lifting of bulky packages.
- Equipment arrangement
- Mobile-base pneumatic industrial manipulator
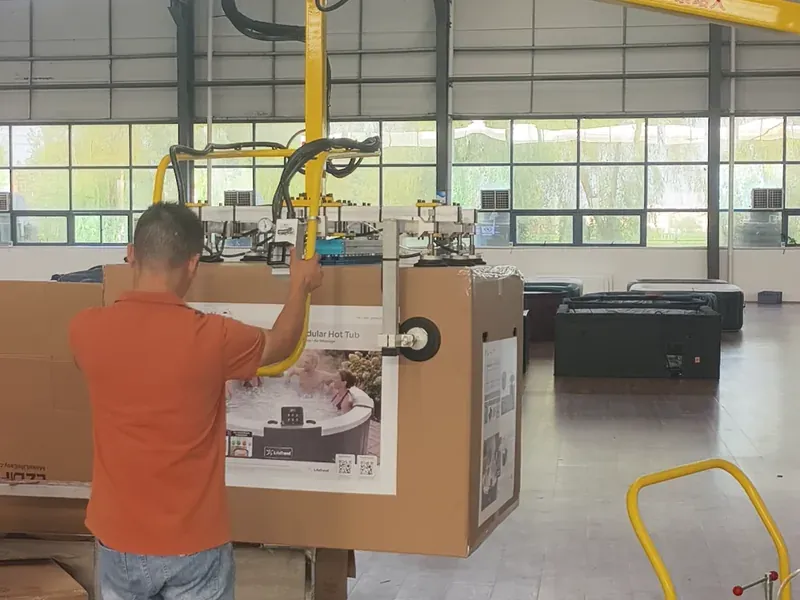 Large-box handlingWatch on-site video
On-site video
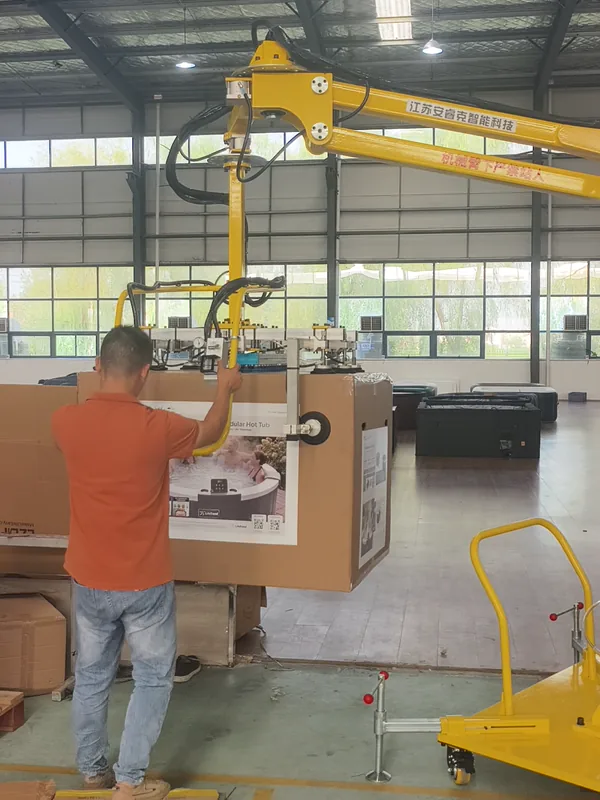 Watch the full video on WeChat Channels
On-site footage
A mobile-base pneumatic industrial manipulator with custom vacuum tooling using side and top suction cups assists with pickup, lifting, direction changes and placement of large packaging boxes. The operator guides box transfer, reducing manual carrying and lifting of bulky packages.
Open WeChat Channels ↗Application overview
Large packaging boxes offer limited holding space, and their size and orientation can restrict manual lifting and direction changes. AUREK combines a mobile-base pneumatic industrial manipulator with custom vacuum tooling using side and top suction cups to connect pickup, lifting, direction changes and placement. After the base is positioned at the operating location, the manipulator carries the handling load while the operator guides the box within its working range.
System configuration
| Workpiece | Large packaging boxes and bulky box-shaped loads |
|---|---|
| Equipment arrangement | Mobile-base pneumatic industrial manipulator |
| Tooling | Custom vacuum tooling using side and top suction cups |
| Main motions | Alignment, vacuum gripping, lifting, direction changes, horizontal transfer, placement and release |
| Operation | Handling within the manipulator's working range after the base is positioned and its brake or supports are engaged |
| Workstations | Large-box pick-and-place, transfer within a workstation and packaging assistance |
Configuration features
- Side and top suction cups conform to the box contact areas, reducing manual carrying, lifting and changes of hand position during transfer.
- The manipulator carries the box handling load while the operator uses a handle to guide lifting and direction changes, assisting with large-box pick-and-place.
- The mobile base allows the equipment's operating position to be adjusted. Repositioning brings the relevant workstation within reach and accommodates changes in the packaging-area layout.
Operating sequence
- Move the unloaded equipment to the operating position, position the base and engage its brake or supports, and keep the manipulator's working area clear.
- Align the vacuum tooling with the box gripping area and seat the contact surface. Establish the vacuum and check the grip before lifting slowly.
- Keep the base at its operating position. Use the handle to guide horizontal movement and direction changes within the manipulator's working range as the box approaches the placement position.
- Lower the box slowly onto the target position. Release the vacuum after the box is stable at the target position, then withdraw the tooling and return to the pickup position.
Selection and configuration
- Gripping area and contact structure can be selected for box dimensions, surface material and local strength, accounting for sealing and load distribution.
- The vacuum source and grip-status monitoring can be selected for packaging-surface flatness and permeability to match the pickup method.
- Adjustable vacuum tooling or quick-change contact components can be selected for box-size changeover. Base and support arrangements can be selected for the workstation layout.
Frequently asked questions
How is the mobile equipment moved to another operating position?
After placing the box and releasing the vacuum, move the unloaded equipment to the next operating position. Position the base again and engage its brake or supports before vacuum pickup and handling at that location.
How is vacuum tooling selected for large packaging boxes?
The gripping area, contact materials and suction cup layout are configured for the box dimensions, surface condition and local strength. Adjustable vacuum tooling or quick-change contact components can be selected when handling a wider range of sizes.
More cases
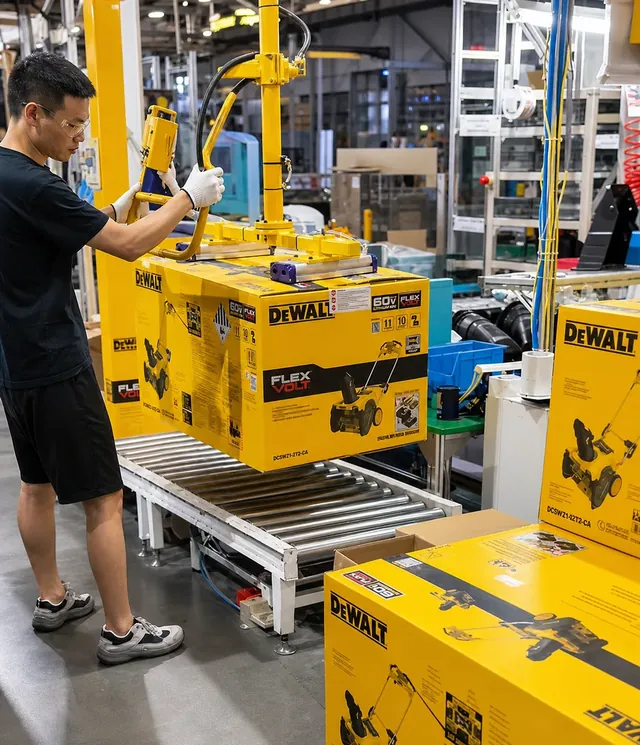 Carton stackingOn-site videoCarton Vacuum Handling and Stacking ApplicationA pneumatic industrial manipulator with vacuum tooling picks up, lifts, transfers and stacks packaged cartons. One operator guides the carton position using the operating handles, reducing repeated manual carrying and lifting.
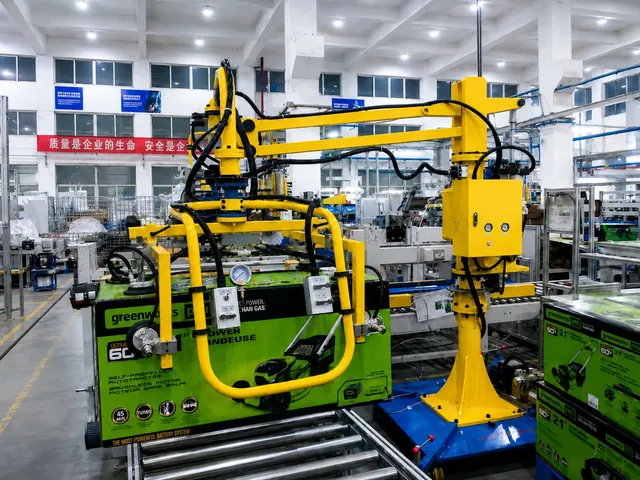 Carton vacuum handlingCarton Vacuum Handling ApplicationA mobile-base pneumatic industrial manipulator with vacuum tooling picks up, lifts, transfers and places cartons, reducing repetitive manual carrying at packaging lines and box-transfer stations. The equipment can be positioned for the operating location.
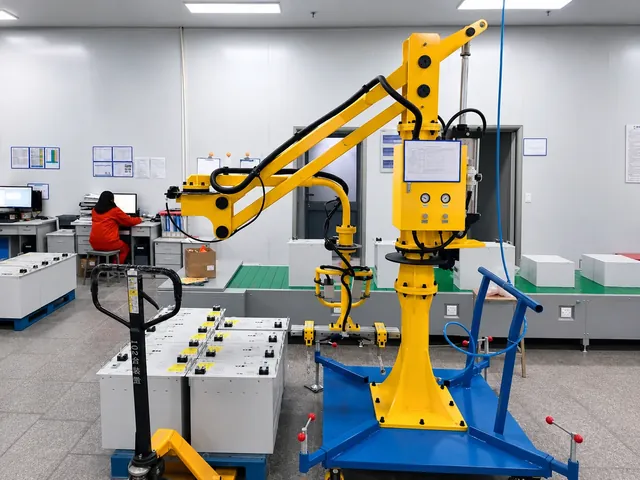 Power supply packing and handlingPower Supply Packing and Handling ApplicationA mobile-base pneumatic industrial manipulator with custom tooling and a dedicated cart assists with gripping, lifting and packaging transfer of power supply products. It reduces repetitive carrying and allows different packaging areas to share the equipment at different times.
Submit your requirements, get a technical proposal
Share the workpiece name, weight per workpiece, dimensions and pick-and-place motions, and an engineer will recommend a manipulator arrangement, working range and end tooling. Drawings and site photographs can be sent by email or WeChat.
