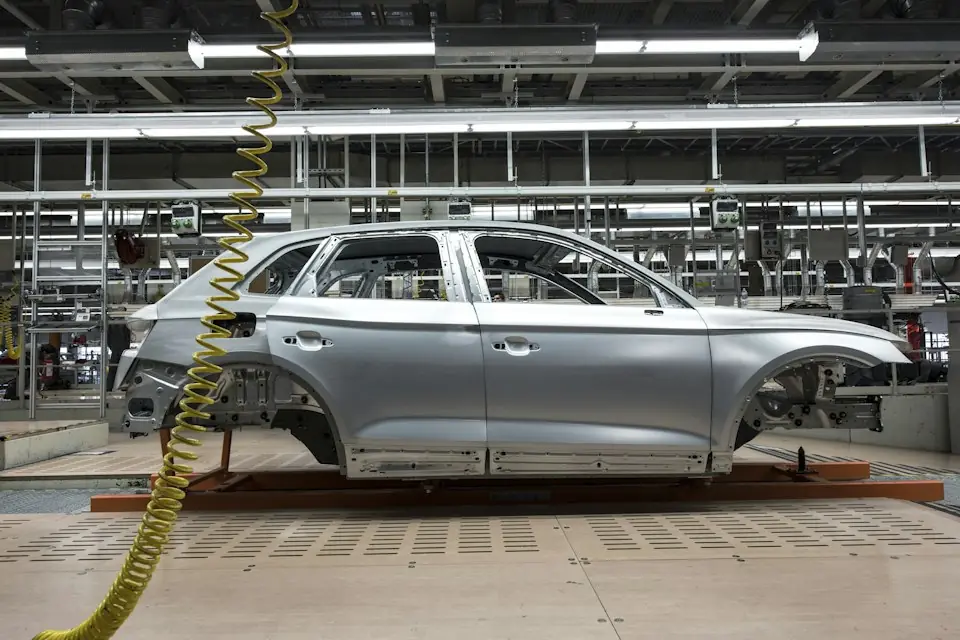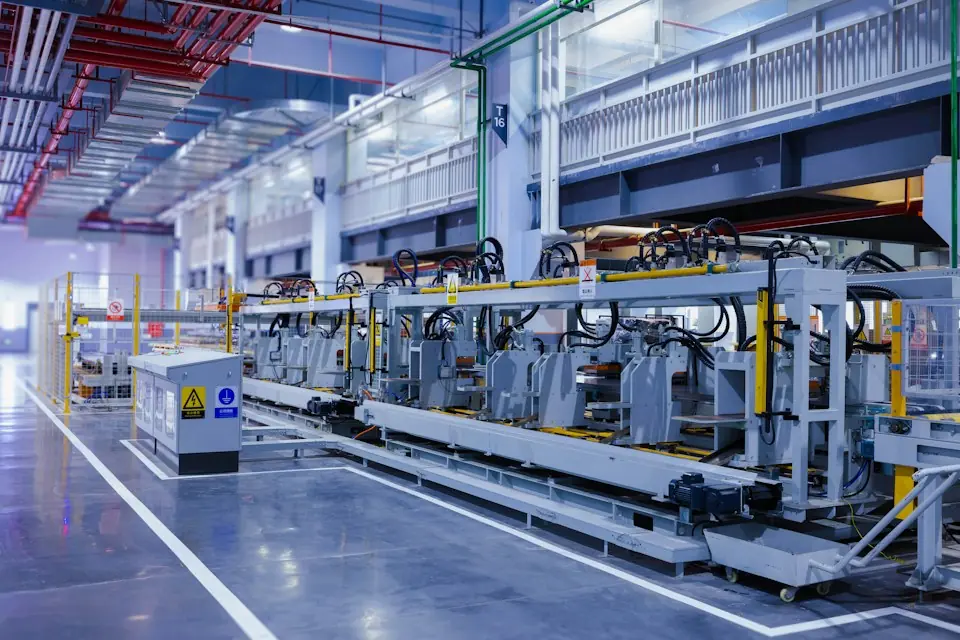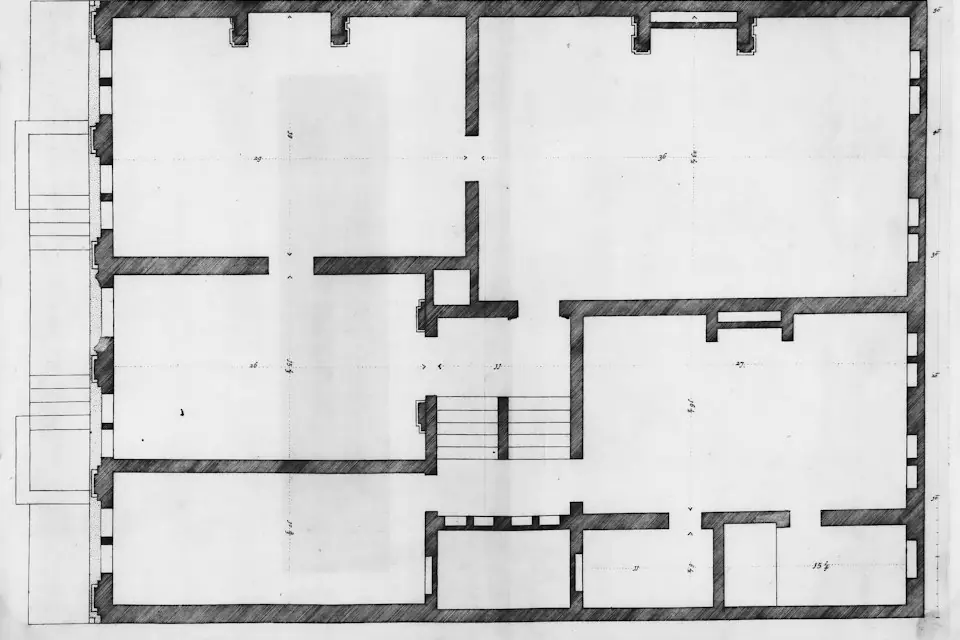
- Welding-station clearance planning must include fixed obstructions, dynamic envelopes and temporarily occupied areas, as well as equipment at rest.
- Plan handling paths around tooling approach, workpiece swept space and operator visibility.
- Near robots, welding guns and locating fixtures, define pickup/placement permission and withdrawal confirmation.
- Verify the final design with actual tooling and workpieces through low-speed path checks and tests at limiting operating conditions.
Locating tooling, clamps, welding guns, robots, fences, conveying equipment and repair-welding areas occupy space at different stages. After confirming that the manipulator reaches the pick and place points, check loaded rotation, flipping and withdrawal paths, establishing spatial relationships from each machine's motion sequence.
01Three categories of potential interference
- Fixed obstructions: columns, fences, control cabinets, fixed supports, cable trays, trenches and walls.
- Dynamic envelopes: robots, welding guns, turntables, clamps, lifting locating pins, machine doors and conveyor pallets.
- Temporary occupancy: maintenance platforms, tip changers, gun-cleaning stations, racks, tool carts, welding-wire drums, operator positions and abnormal-condition work areas.
Include all three object categories in plan and height analyses. Add site cable dress packs, valve manifolds, junction boxes and temporary materials to the 3D model so that a path clear in the model does not interfere on site.
02Define pickup, placement and timing conditions
Define each pick-and-place permission condition individually: robot withdrawn, welding gun in a safe position, clamps open, locating pins in the correct state and conveyor pallet locked. Associate each condition with an equipment position and signal. Do not replace them with an ambiguous overall completion signal.
For shared space, define the entry and withdrawal sequence and the safe state of both systems after signal loss. Prefer actual position or zone-state confirmation of manipulator withdrawal; do not rely solely on an operator's button request.
03Select the mounting location for clearance
Choose the mounting center to balance pick-and-place coverage, maintenance access and personnel aisles, minimizing travel across robot areas. A column too close reduces maintenance space; one too far away increases arm length, inertia and swept area. Where floor space is congested, compare overhead or rail-mounted options and also review overhead beams, welding-fume ducts, cable trays and the envelope above robots.
Include the manipulator body, end gripper and largest workpiece in the model. For large parts such as doors, body sides and battery trays, pay particular attention to clearances between their outer edges, fences and welding guns.
04Plan approach to locating pins and clamps
During placement, complete the large movement first, then approach the tooling over a short distance with low inertia. Locating pins provide final location; they must not correct large angular errors or withstand forceful sideways pushing. Coarse positioning may use guide surfaces, visual datums, mechanical compliance or operator prompts, selected through tolerance and process verification.
Envelope analysis must include the swing-arm position of open clamps. The open state may occupy more space than the clamped state; use it to select manipulator approach and withdrawal directions.
05Welding-gun and accessory clearance checks
| Item | Required checks | Common omissions |
|---|---|---|
| Robot welding gun | Production, home, maintenance and abnormal-stop positions | Checking only the home position |
| Welding gun cable package | Bending and swinging envelopes | Only the rigid welding gun is included in the model |
| Tip-changing / gun-cleaning equipment | Robot entry and exit paths and maintenance spaces | Treating these as fixed, compact equipment |
| Repair welding tools | Suspension lines, tool balancers and personnel arm reach | Omitting them from the layout |
| Welding slag and heat source | Protection of hoses, suction cups and sensors | Checking geometry without thermal protection |
06Hoses, cables and handles also have motion envelopes
Secure air hoses, cables, vacuum lines and control handles along the structure, allowing controlled movement at each joint. Check for snagging and fitting tension throughout the full travel. Near welding areas, choose sleeves and routing based on slag, spatter, radiation and sharp-edge locations.
07Fences, personnel and maintenance spaces
Fences also define hazardous areas. If the manipulator, gripper or workpiece crosses a fence, the overall risk assessment must determine isolation and interlock requirements. Operator positions must provide a clear view of the gripper, workpiece and locating points. Operators must not lean into a hazardous area to inspect pin holes.
Preserve access for welding-gun maintenance, gripper replacement, valve servicing and tooling cleaning. Check maintenance and production states together so that routine service does not require removing the manipulator.
08Verification from model to site
- Check manipulator, tooling, and workpiece envelopes in two-dimensional and three-dimensional layouts.
- Verify permitted states of robots, welding guns, clamps and conveyors.
- Run the complete route without a load at low speed; mark minimum clearances and visibility blind spots.
- Cover the largest dimensions, most unfavorable centers of gravity, and flipping postures with representative workpieces.
- Verify motion inhibition for incorrect states, communication loss and equipment that has not withdrawn.
- Incorporate final limits, paths, signals and checkpoints into the deliverables.
The clearance-planning deliverables should correspond to verified layout, process, control and safety results, covering moving equipment, temporary obstructions and abnormal states. Confirm the model with actual loaded trajectories on site and include limits, paths, signals and inspection points in the operating documentation.